Product

Exactly what your floor needs —
and nothing more.

An arm, self-enumerating modules, and a control suite. Designed and built in-house, built for Indian factory floors, and programmed by voice on-site.

01 · The arm

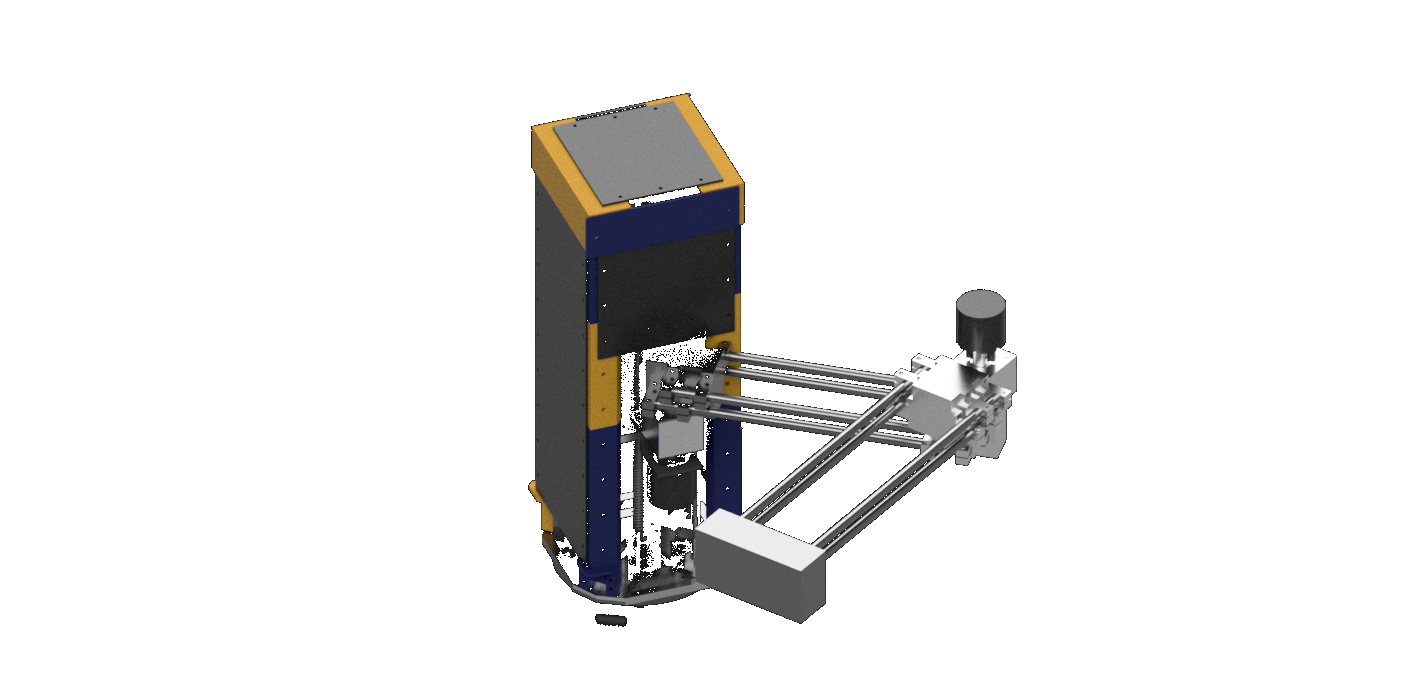
Piqoid Swift

ArchitectureReverse-SCARA
Reach600–900 mm
Axes3 + 2
Payload10 kg
Speed30 cycles/min
Onboard intelligenceVision + edge compute + dynamic replanning
TasksMachine tending · material handling · metal cutting · welding
swift · assembly
Piqoid Swift reverse-SCARA arm assembly reverse-SCARA · 3+2 axes
02 · The modules

Integration priced as a component,
not a project.

Self-enumerating modules: plug one onto an old machine and the robot's brain reads its torque, travel and specs automatically — giving decades-old machines a signal path without touching their electronics. No PLC to hunt. No protocol to reverse-engineer. No army of scarce integration engineers.

Minutes to fit

Motor & joint modules

Clamp on, and the machine becomes legible to the robot — its quirks and limits read automatically instead of an engineer tracing wires for weeks.

No rewiring

Your machines stay untouched

The modules sit alongside the machine's existing electrics. Nothing is cut, replaced or re-certified.

Every machine level

Manual to CNC

Modules bring fully manual and motorised machines into robotics; the harness makes controller-equipped machines deployable in days.

03 · The control suite

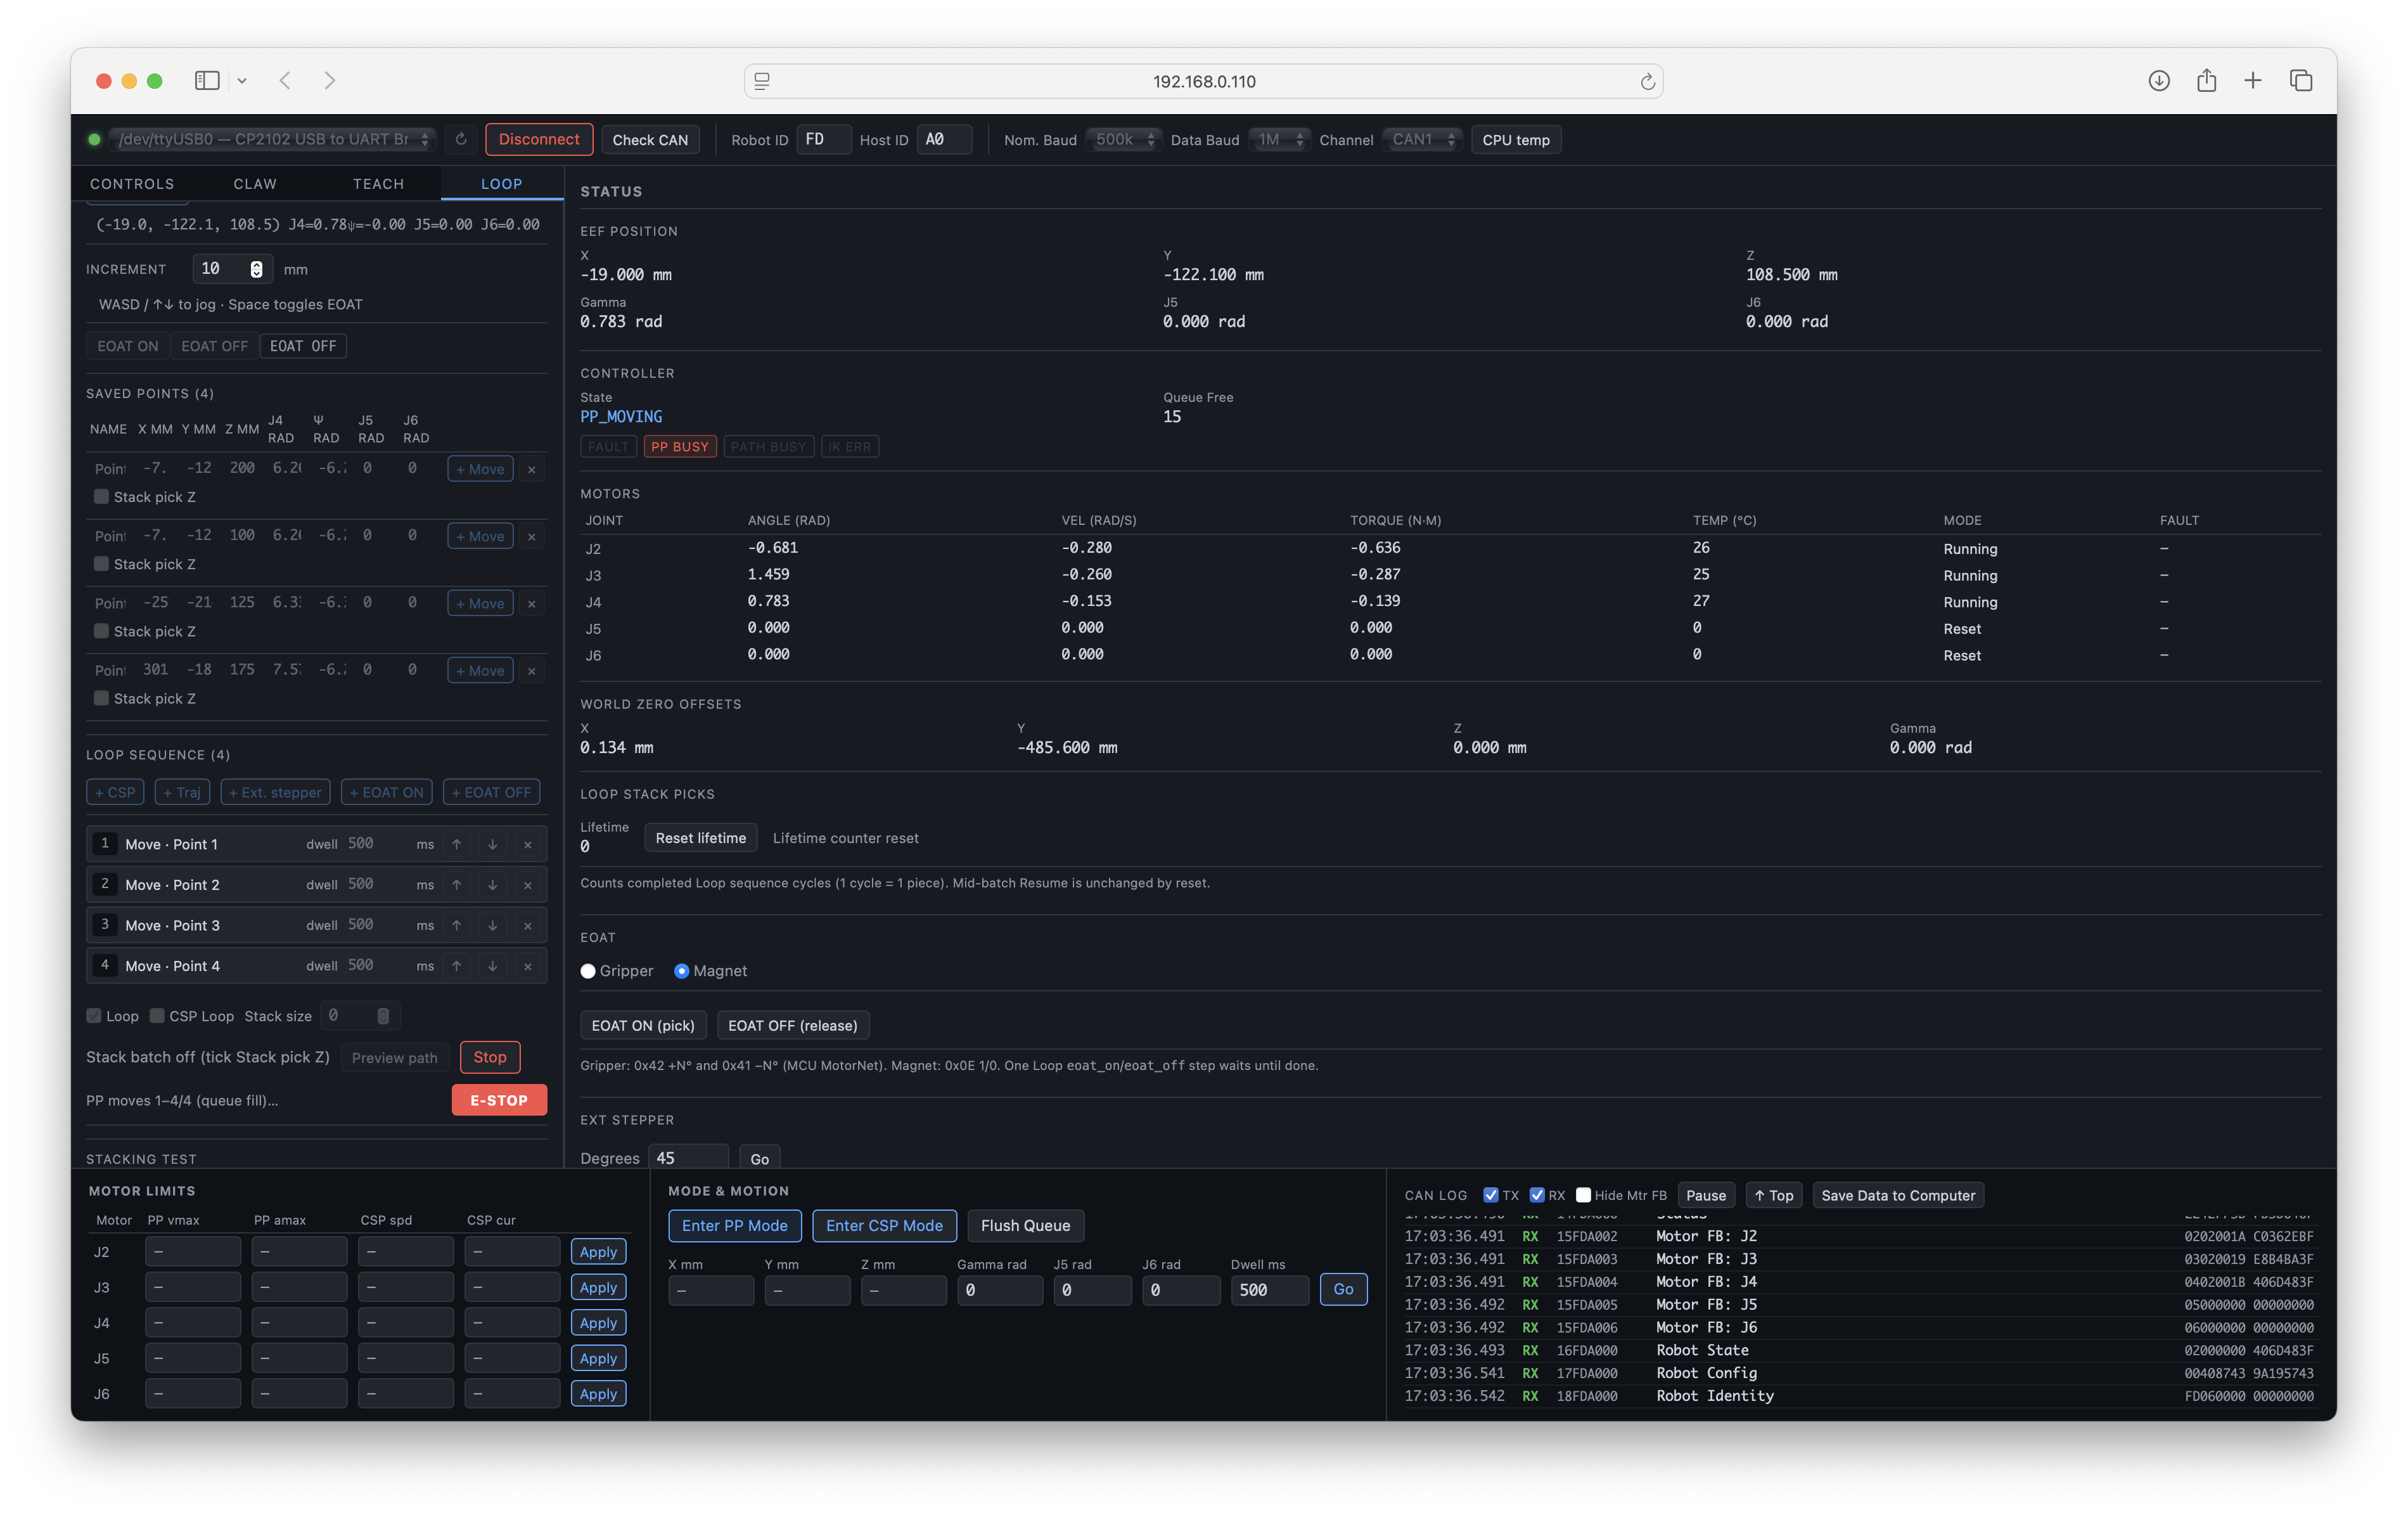
Piqoid Nexus. One interface. Every machine.

The unified desktop suite for configuring, calibrating and coordinating Piqoid robots and any external machines they operate alongside — from conveyors to CNC to third-party actuators.

01

Motor & joint configuration

Torque limits, PID tuning, joint homing, encoder calibration — for our arms and any servo-driven machine in your cell, from one graphical interface. No terminal required.

02

Cross-machine interoperability

Coordinate the robot with the machines around it — timings, handshakes, I/O mapping — without a PLC expert.

03

Live telemetry & diagnostics

Joint torque, current draw, contact timing and module health, streamed live for operators.

04

One-click deployment & rollback

Publish a cell configuration or roll it back — designed so a factory technician can own it, not just an automation engineer.

< 120 min first robot online · ∞ machine types · 0 code required

nexus · control suite
Piqoid Nexus control suite unified machine control
04 · The harness

Programmed by voice.
Corrected by the operator.

01

Describe the task

The operator speaks the task; the workspace is scanned with a phone. No teach pendant, no code, no CAD.

02

AI designs the cell

Fixtures, rigs, mounts and safety layout — generated from pre-qualified components, not drawn by an engineer.

03

Paths written on-site

The harness writes the motion paths in minutes; the operator corrects by talking; our field engineer signs off.

04

Handover, not dependency

Your team owns the cell from day one. New part or new machine? The same voice-first process, in minutes.

"Same robot, same machine, two approaches: an integration SI quoted weeks of engineer time. The Piqoid harness did it in 35 minutes."
Press-bend tending · field measurement
Live demo

Your task, on our robot.

Bring a part or a photo of your machine. We'll show you the cycle — live, on real material.